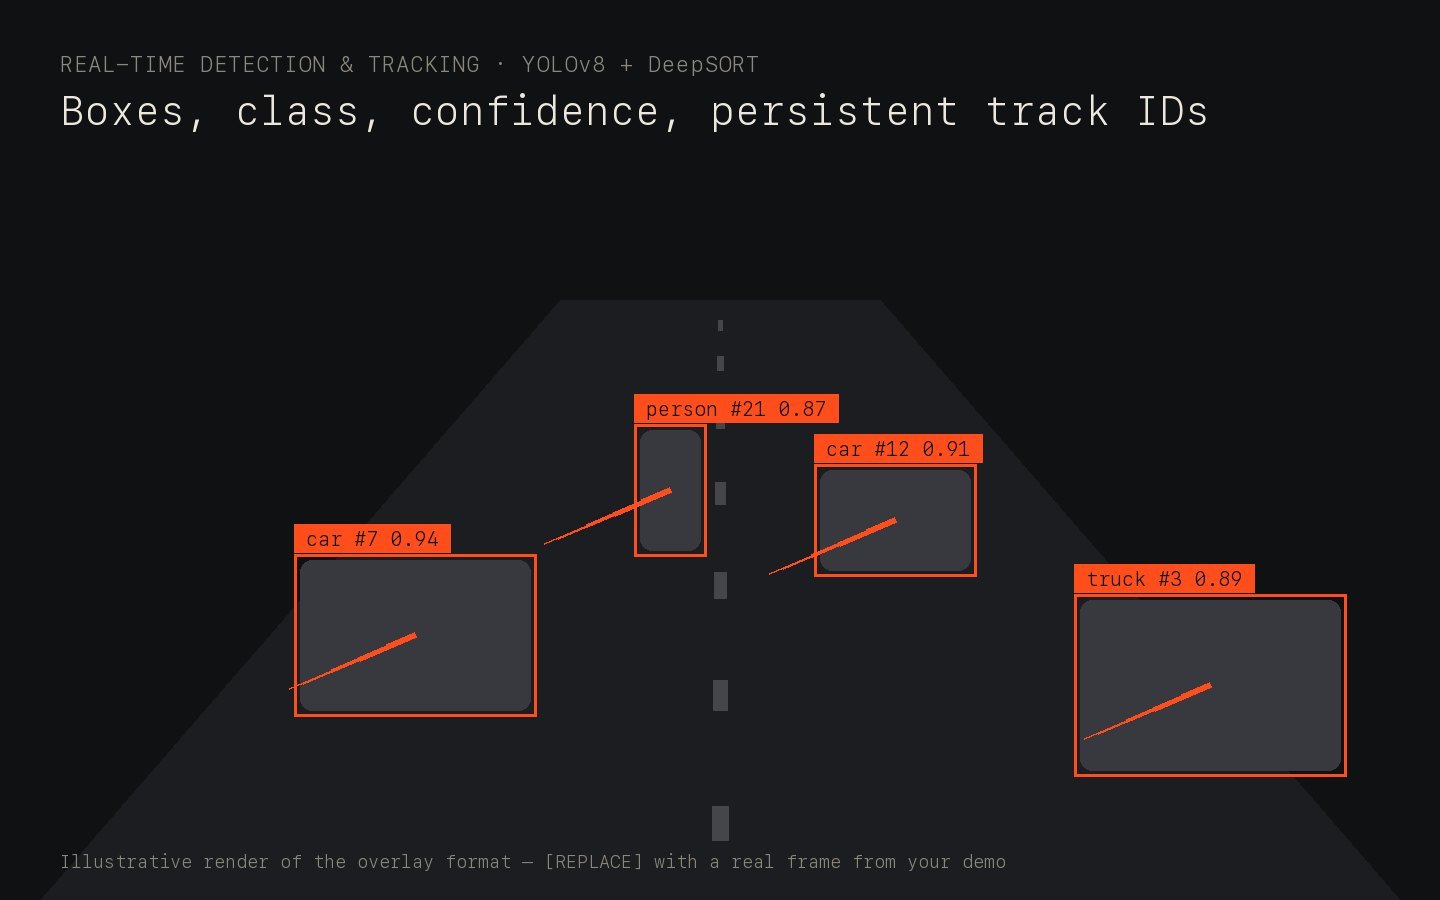
Detection with identity-preserving tracking, exported to ONNX and compiled with TensorRT.
- My role
- Solo
- Links
- GitHub (planned) ↗
- Stack
- PythonOpenCVONNXPyTorch
- Python · YOLOv8 · DeepSORT · OpenCV · ONNX · TensorRT
- Microsoft-ecosystem fit
▸ ONNX export (portable to ONNX Runtime)
94%
Detection accuracy
[REPLACE]
FPS before → after TensorRT
Source · Illustrative render of the overlay format. [REPLACE] with a real frame from your detection demo
01 — Problem
Accurate detectors run slowly on edge hardware, and fast detectors lose track of objects between frames.
02 — Approach
- 01
YOLOv8 + DeepSORT for stable identities.
- 02
ONNX export, TensorRT engines for edge devices.
03 — Architecture
System architecture
S01
Camera
S02
YOLOv8
S03
DeepSORT
S04
ONNX → TensorRT
S05
Overlay
04 — Engineering notes
From PyTorch to the edge
# Simplified export path
from ultralytics import YOLO

model = YOLO("runs/detect/train/weights/best.pt")
model.export(format="onnx", opset=12, simplify=True)   # portable: ONNX Runtime, TensorRT
model.export(format="engine", half=True)               # TensorRT FP16 engine for the device
DeepSORT runs on the detections each frame, so an object keeps its ID through brief occlusions.
Outcome
94% detection accuracy with consistent object identities across frames.
Next project
PINN · Seismic Response